My Projects
I have had the great privilege of working for many of the most forward thinking and established student organizations at Texas A&M, as well as an electrical installation intern at ProLift. All of these great experiences taught me valuable lessons that go far beyond engineering, including people skills, leadership, project management, and bringing passion to a team.
ProLift Work Experience
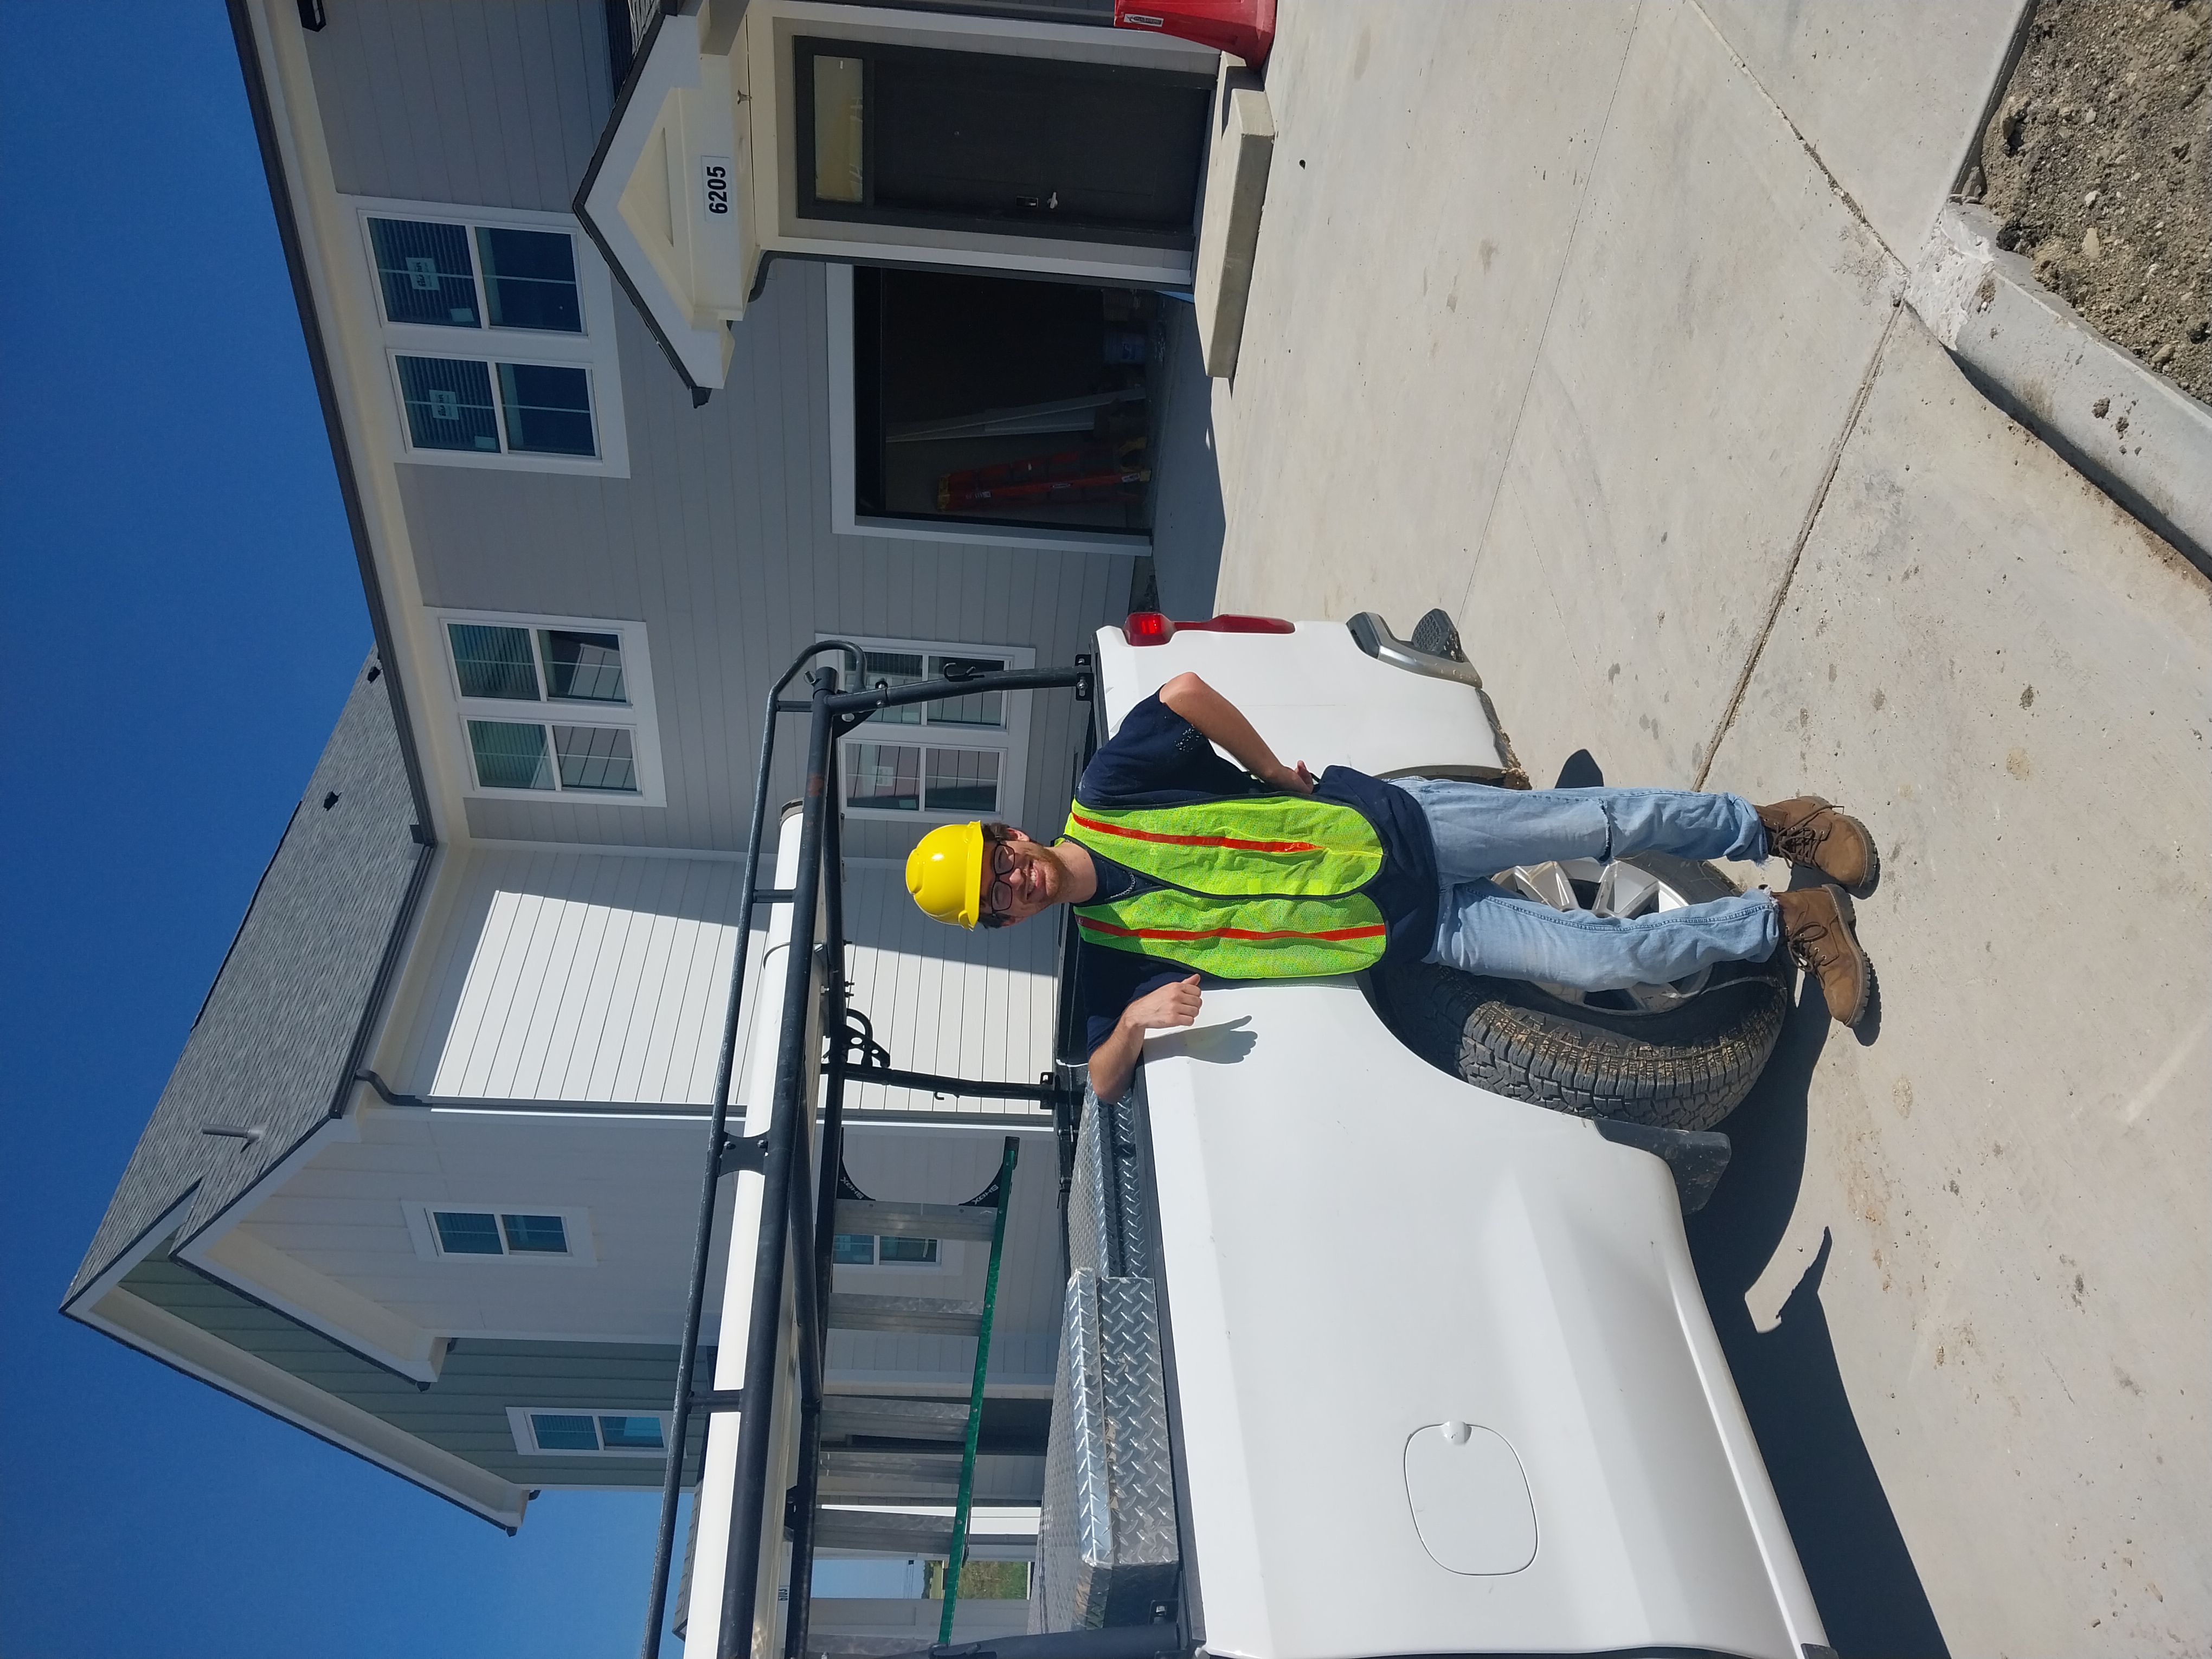
I worked as an electrical installation intern at ProLift, a company that specializes in the design and installation of garage door systems. My work consisted of repairing and installing garage doors for clients in need of doors for commercial, industrial, and residential applications. I learned a lot about the electrical systems of garage doors, as well as how to work with clients and manage my time effectively. My favorite part of this experience was the planning phase. Planning at ProLift followed strict protocols, including outlining safety procedure, enumerating and documenting materials, and then creating an installation plan. Every door is unique, and thus every installation requires an in-depth planning phase. During my time at ProLift, I was a part of about 20 garage door installations over three summers, and my superiors noted that the planning process I helped implement cut installation time by around half.
Turtle Robotics
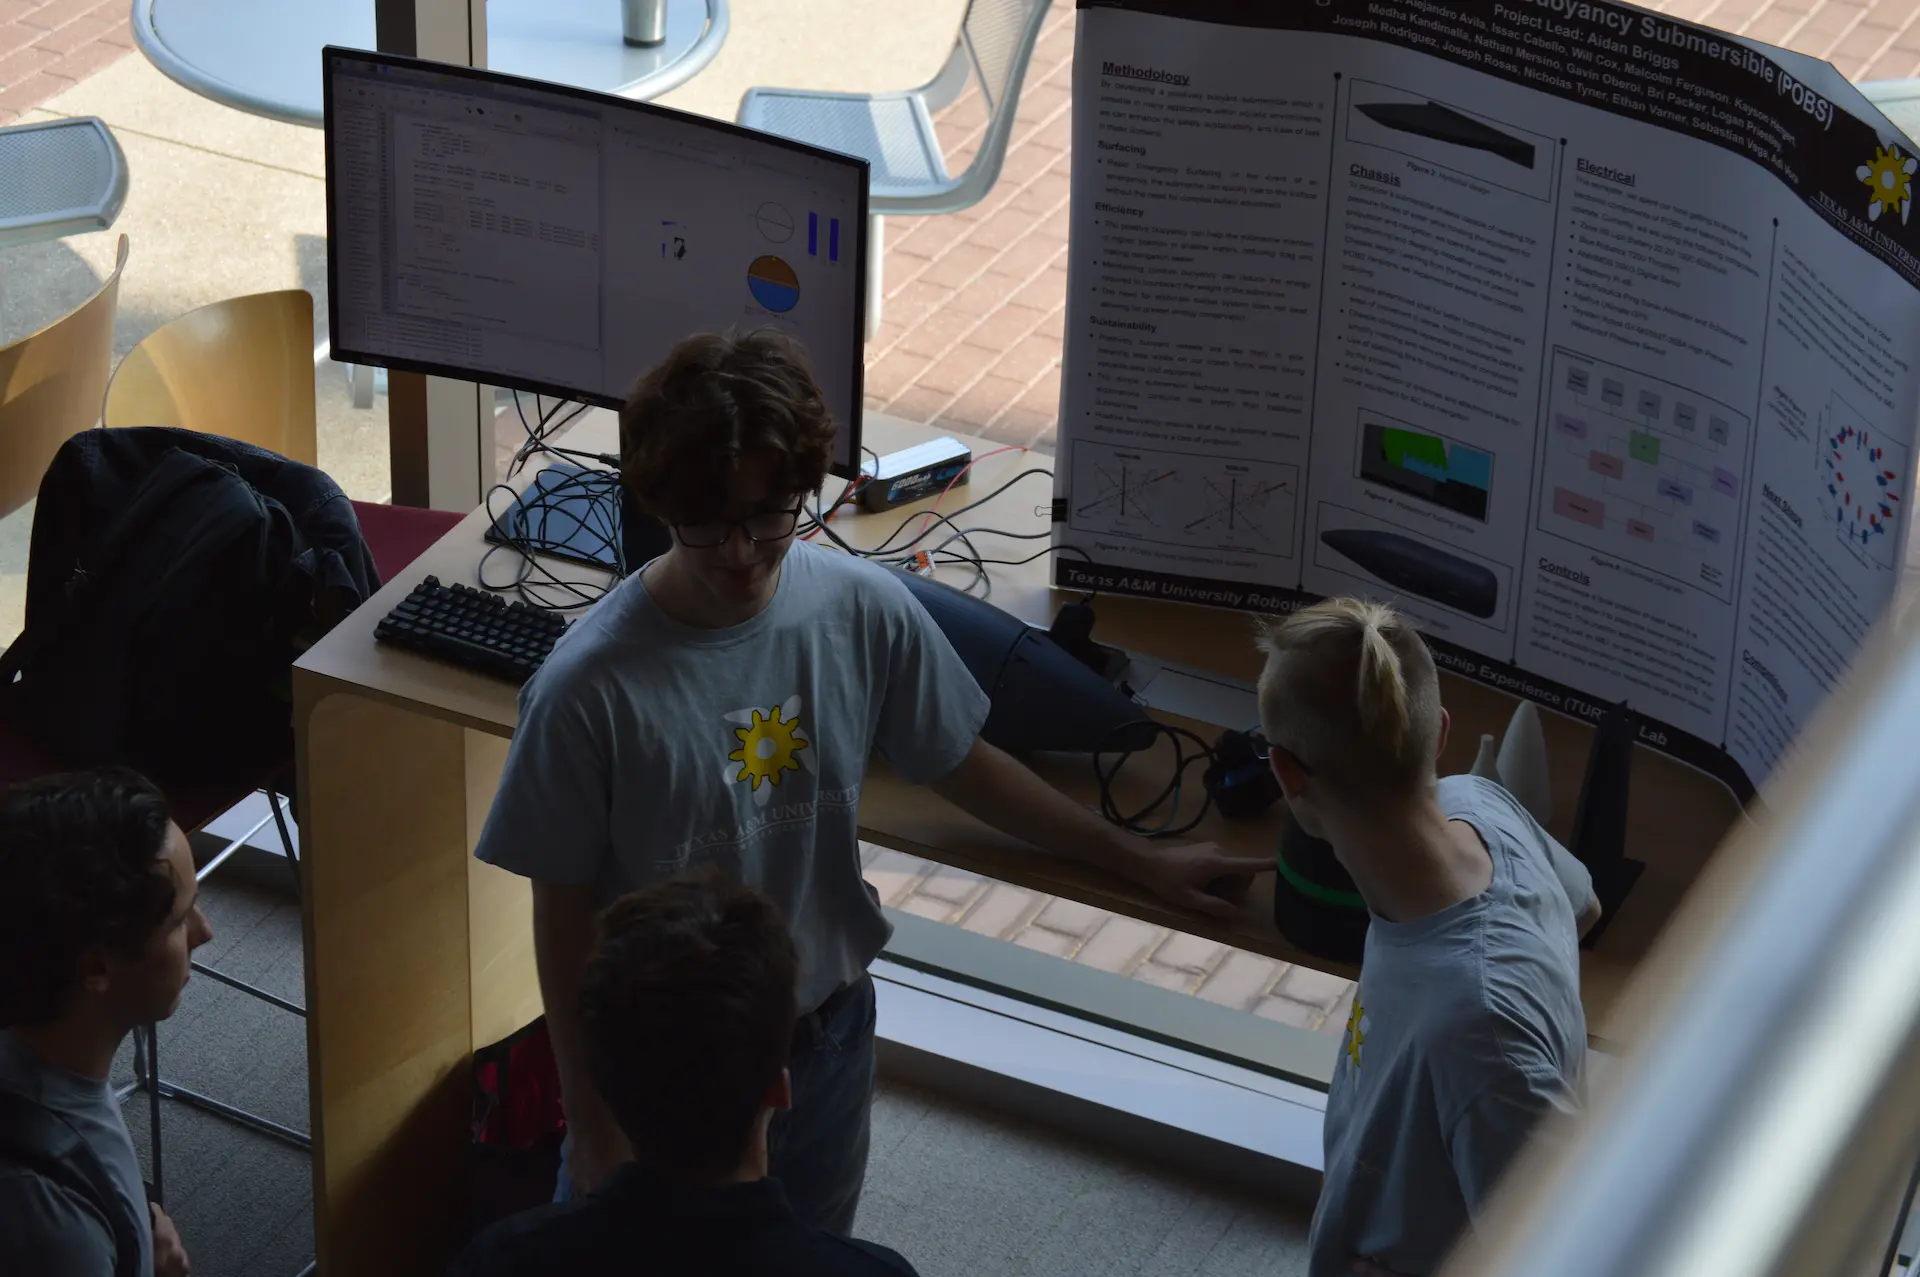
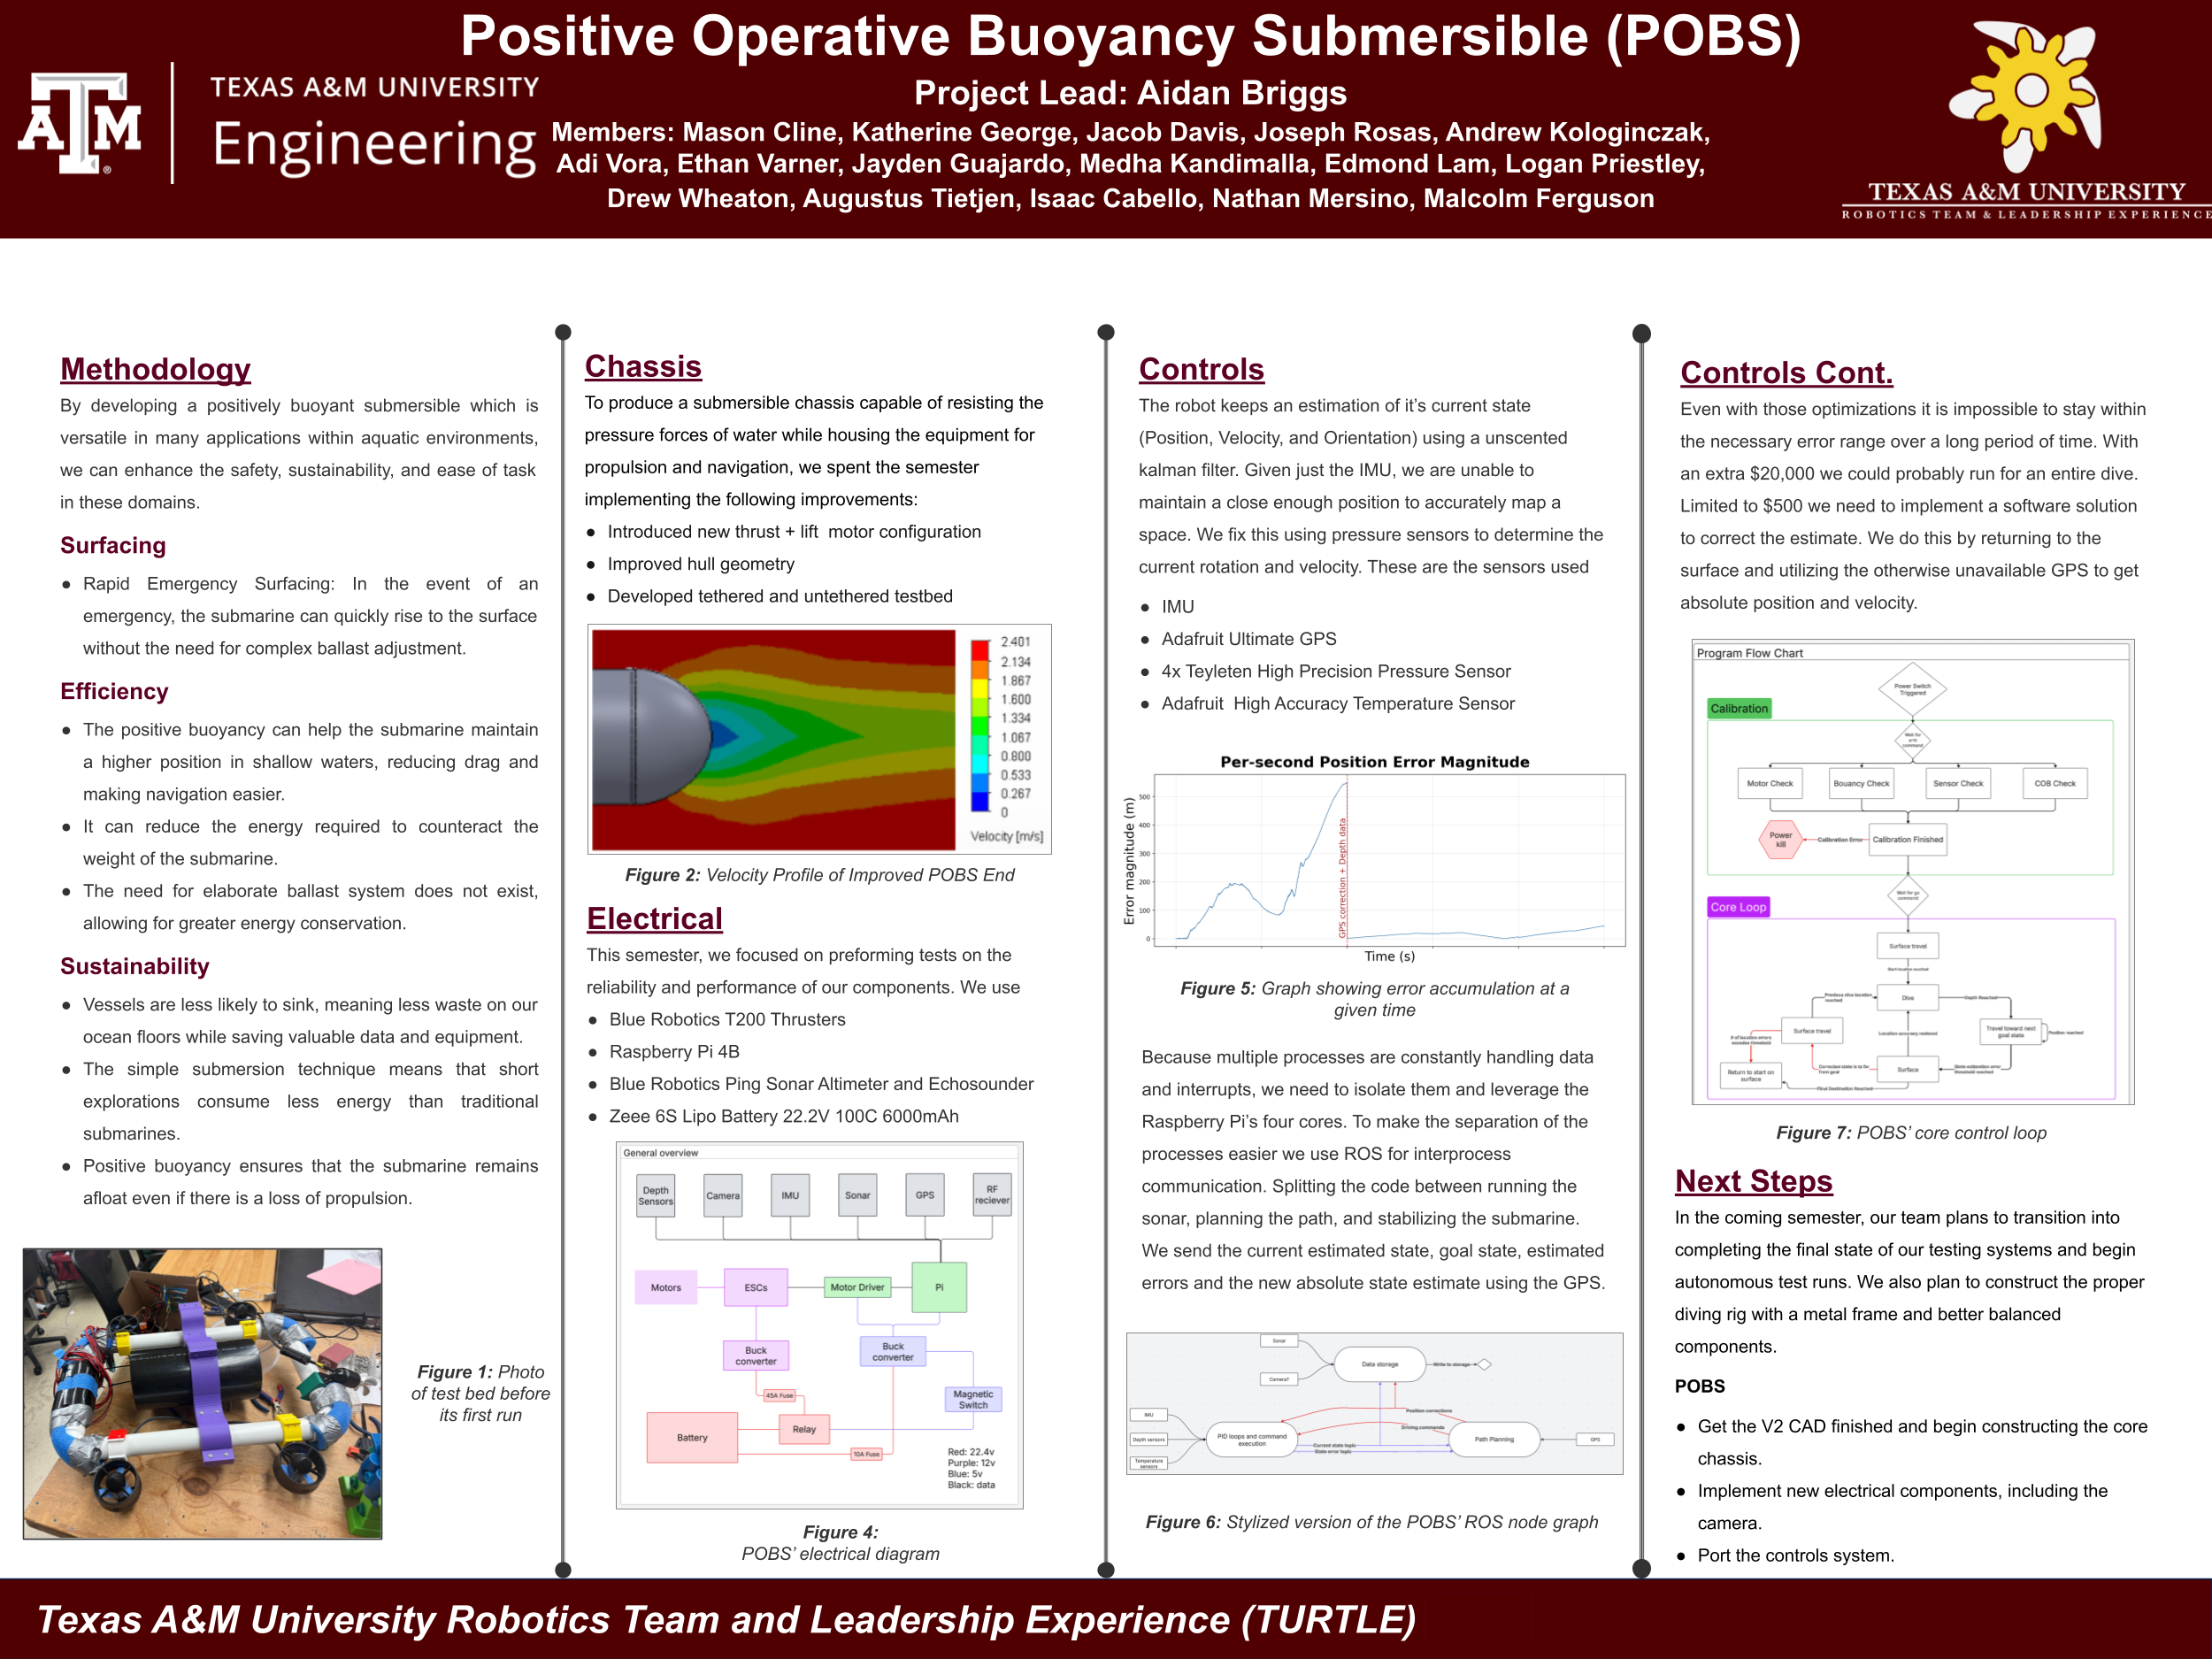
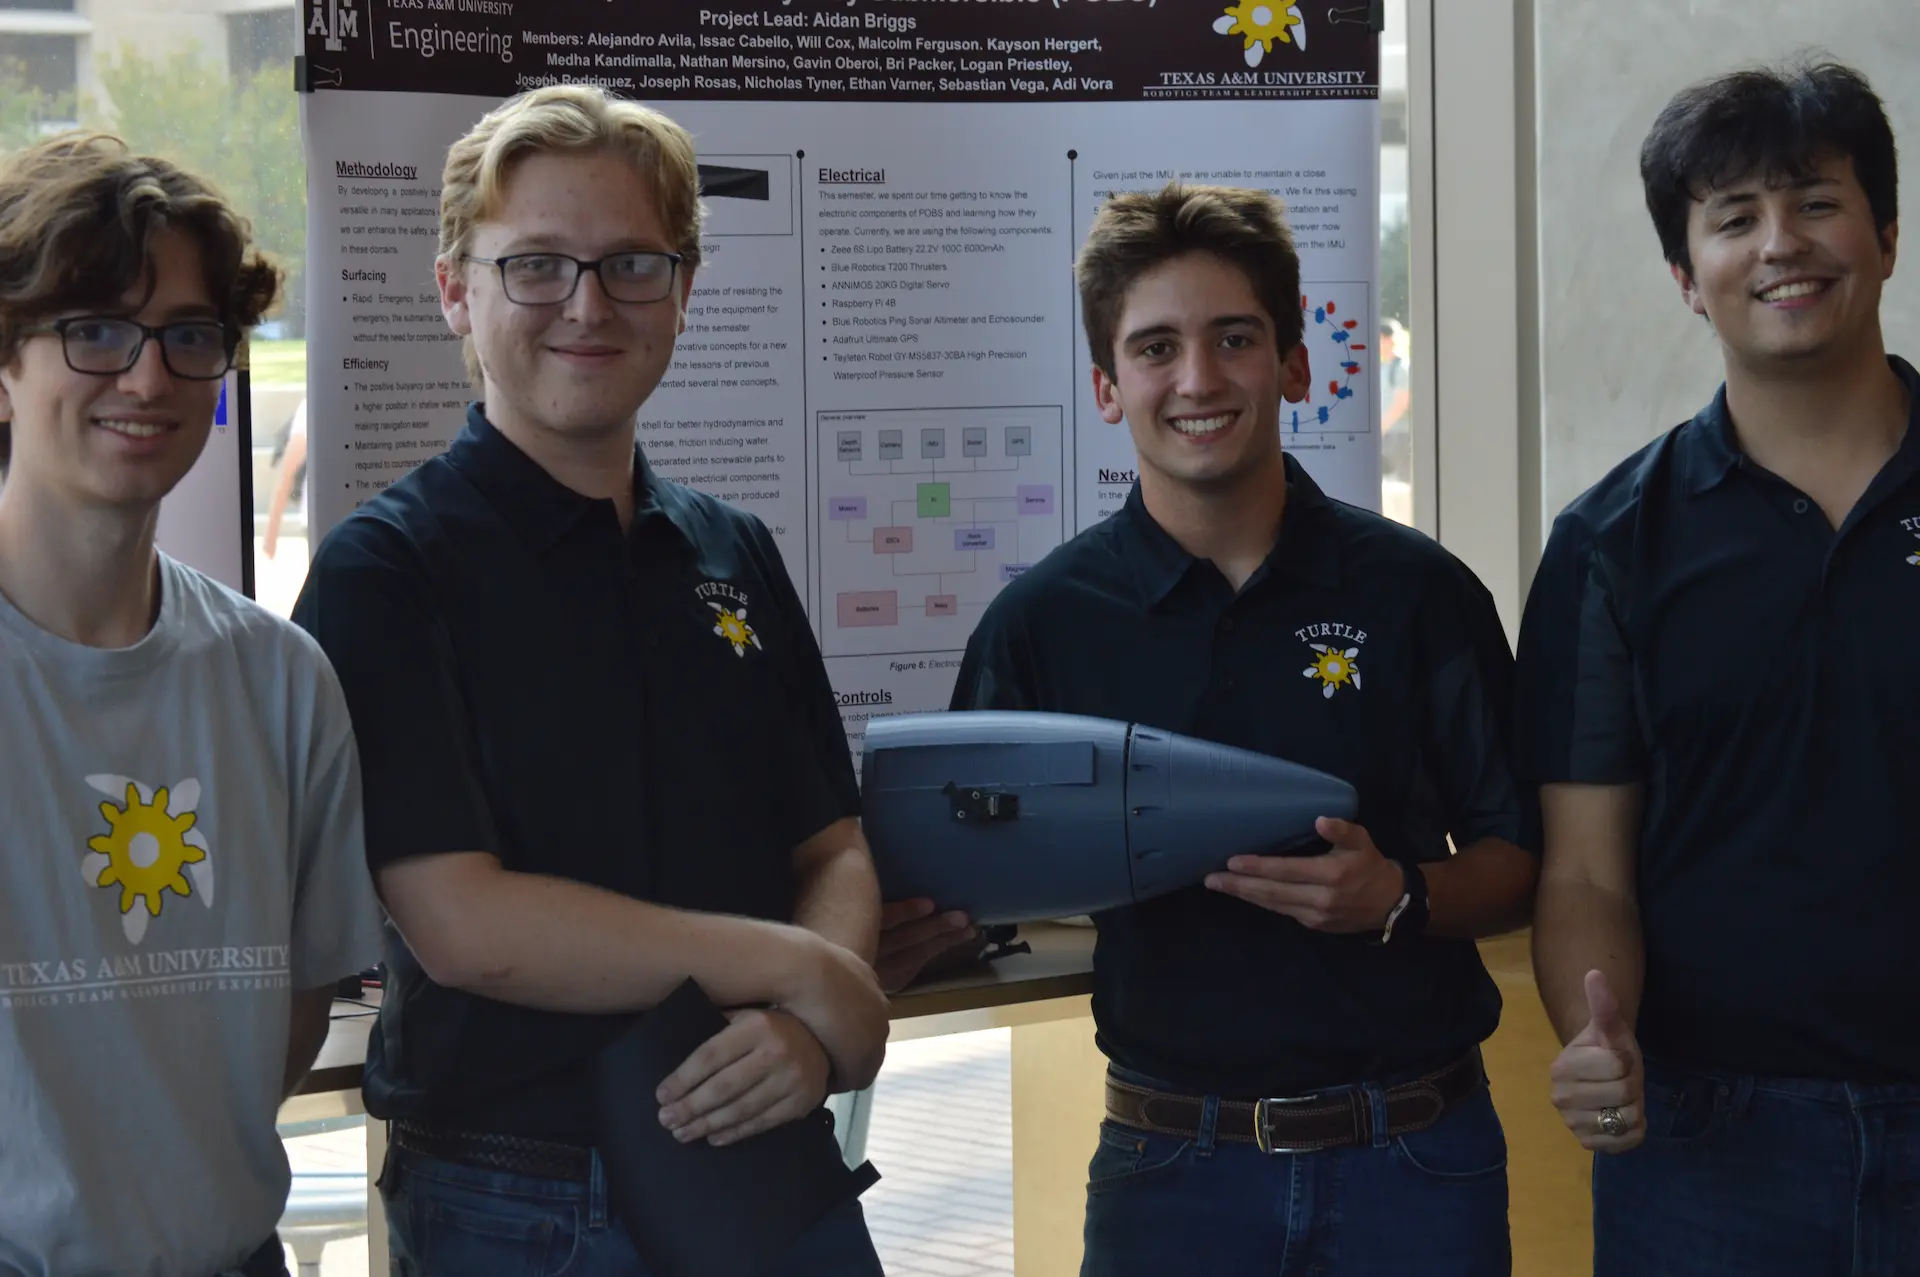
Turtle Robotics is a student organization at Texas A&M that seeks to develop numerous robotics teams and projects into maturity, some teams reach their design goals in a year, others take multiple years. I have been a part of the Positive Operating Buoyant Submarine (POBS) team since Fall 2025, and it is one of the oldest Turtle teams. I will continue my work this year, as I have been promoted to leader of the electrical subteam, where we are moving the next version of the submarine to a Raspberry Pi 5. My work last year consisted of writing motor drivers in C++ using information gathered from the onboard IMU, as well as writing the camera driver so that images can be taken from the perspective of the submarine and sent to the user. I used my soldering experience to connect the motor power supply systems. Additionally, I created a wireless Python server (pyserver) running on the submarine's Raspberry Pi 4 that can be used to observe orientation data and manually control the submarine with about 35 ms of latency. The IMU orientation data also feeds a PID control loop, built in ROS and running on roughly a 100 ms cycle, that drives the thrusters.
Freshman Leaders in New Technology (FLiNT)
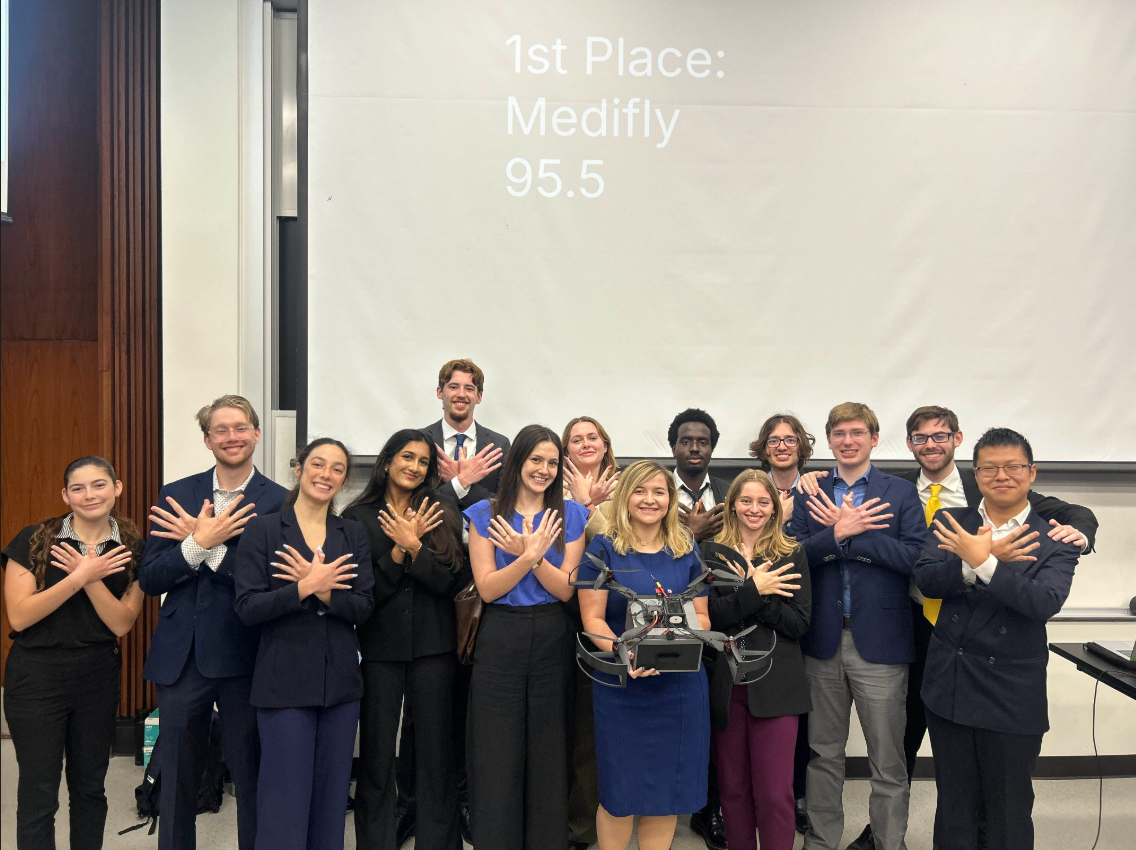
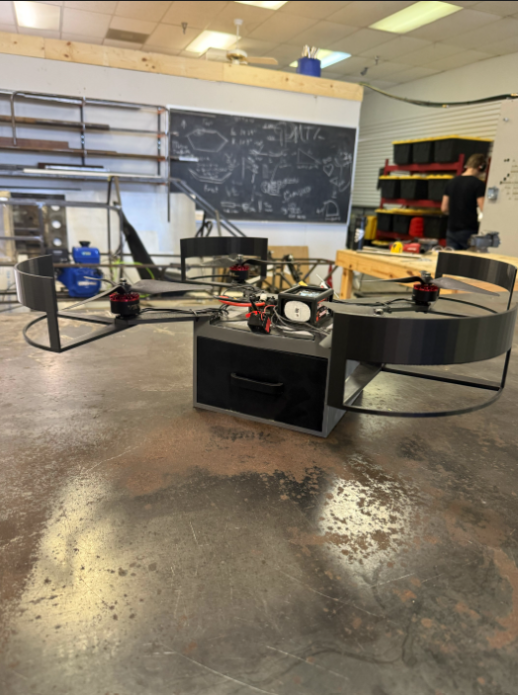
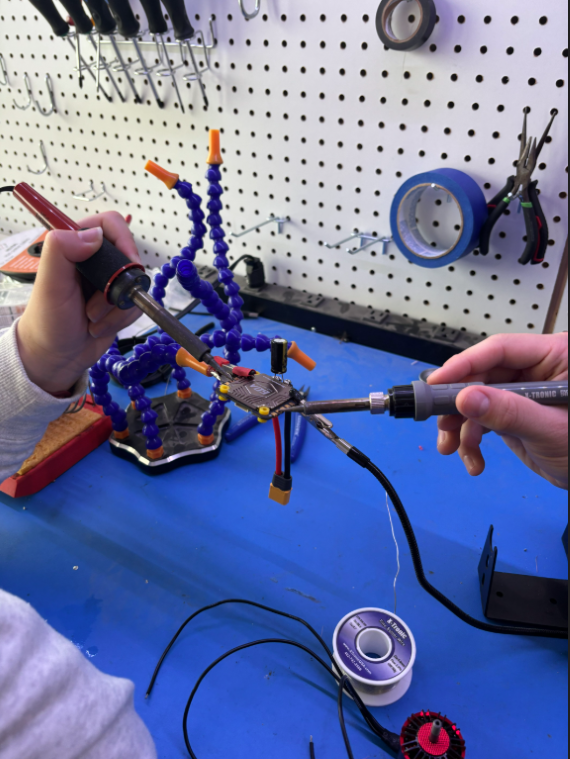
FLiNT is a freshman leadership organization (FLO) at Texas A&M that uniquely has a build team component. During the 2024-2025 school year, I was the electrical design lead for the Medifly project on the aerospace design team, and my goal was to solder electronics and get the software running. Medifly was pitched as a concept drone that would carry common medical devices and have GPS tracking as well as an onboard camera. I connected the peripheral components to the drone's flight controller, soldered motors to the ESC (electronic speed controller, pictured), and set up the calibration and control scheme using SpeedyBee, a common drone flight controller platform. Medifly was pitched to a panel of three judges, two professors and a career professional, and was judged the best project of the year, securing first place.
← Return to Home